RoGaussianOCC
Accurate and robust Gaussian occupancy prediction through temporal fusion and perspective supervision.
Overview
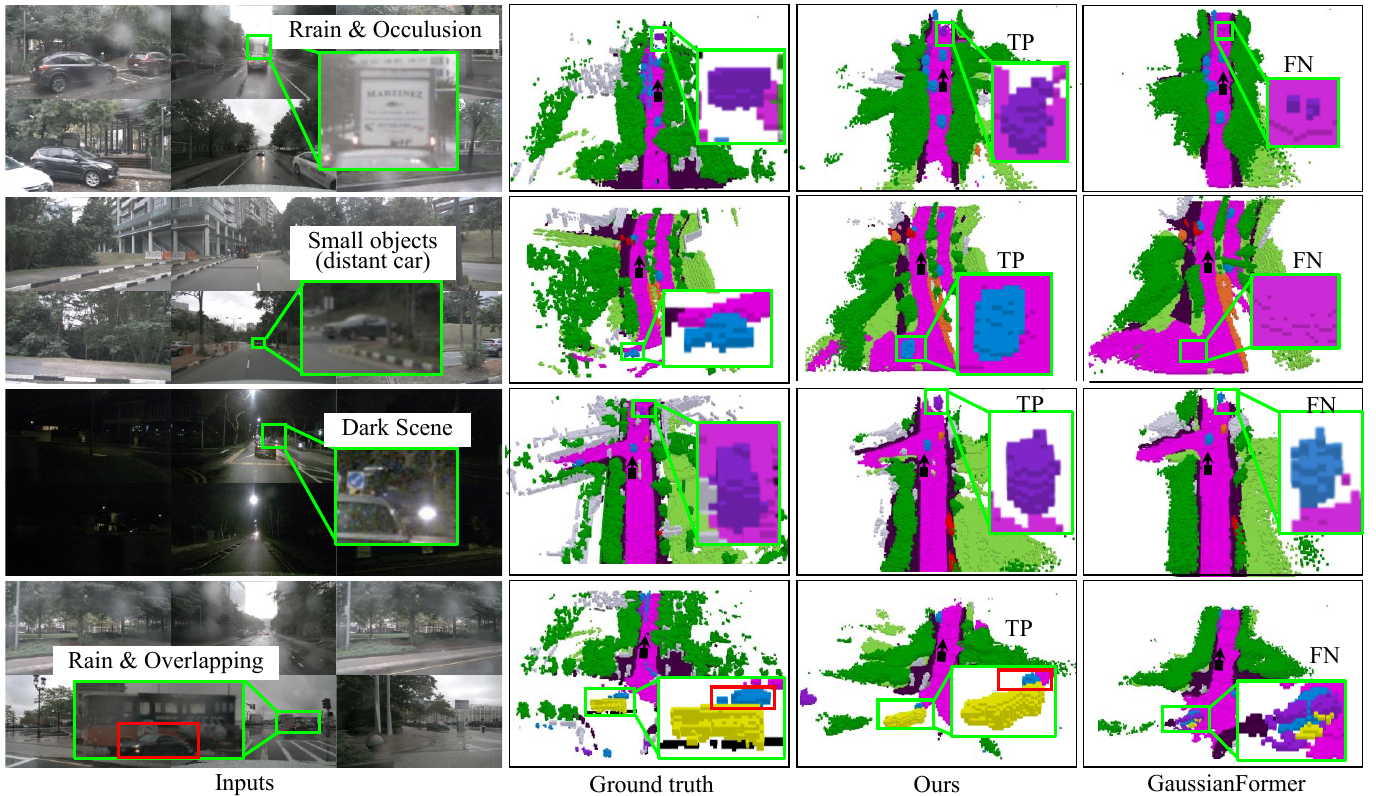
RoGaussianOCC is a camera-based 3D semantic occupancy-prediction framework for autonomous driving. It uses object-centric Gaussians as a compact scene representation and introduces temporal information to address inefficient Gaussian placement, distribution distortion under occlusion, and sparse supervision during training.
My contribution
- Proposed and implemented the complete RoGaussianOCC framework.
- Led model training, parameter tuning, ablation studies, visualization, and project coordination.
- Authored the paper as a co-first author and prepared the public demo and codebase.
Technical approach
Historical Gaussian fusion
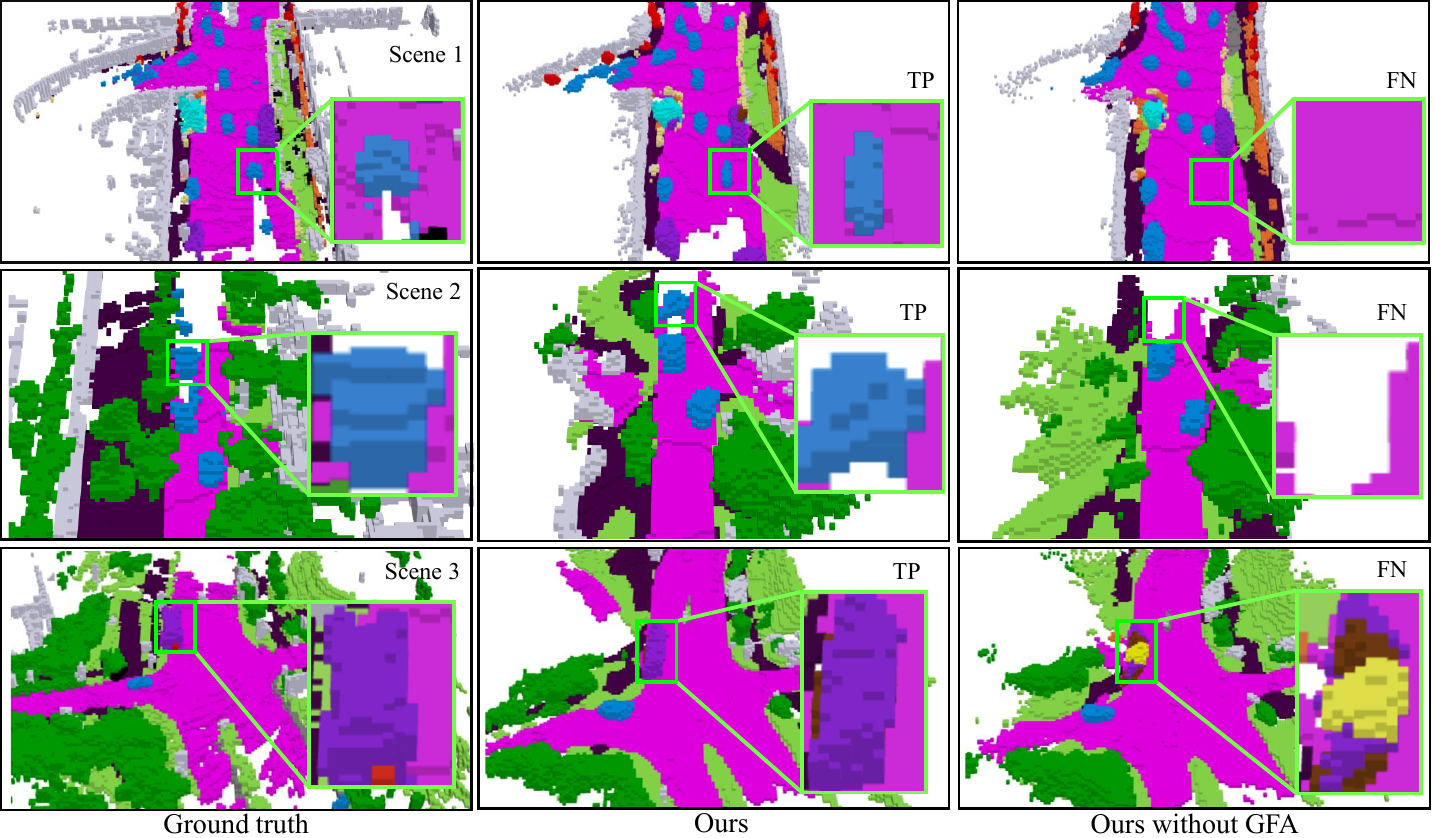
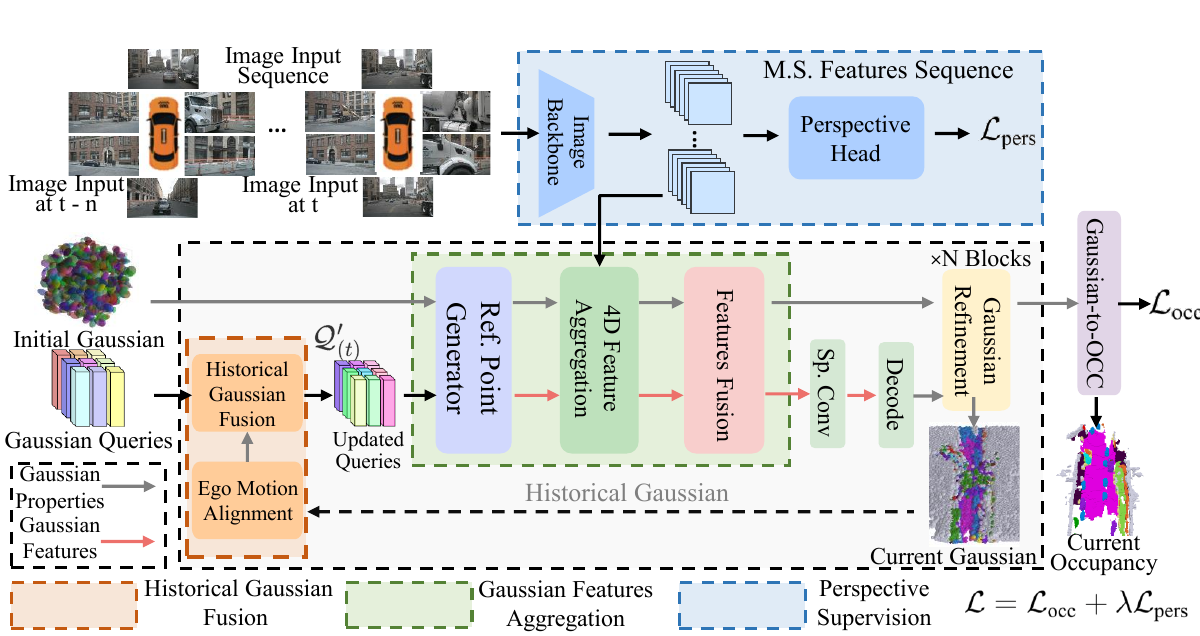
Aligns historical Gaussians with ego motion and fuses prior and current queries to concentrate representation capacity on informative regions.
Aligns historical Gaussians with ego motion and fuses prior and current queries to concentrate representation capacity on informative regions.
Gaussian feature aggregation
Samples continuous multi-frame image features in 4D and fuses temporal Gaussian features to recover occluded objects.
Samples continuous multi-frame image features in 4D and fuses temporal Gaussian features to recover occluded objects.
Perspective supervision
Adds an auxiliary perspective head that provides denser supervision to the image backbone and improves convergence.
Adds an auxiliary perspective head that provides denser supervision to the image backbone and improves convergence.
Gaussian-to-occupancy decoding
Iteratively refines object-centric Gaussians and splats them into a semantic occupancy grid for downstream driving perception.
Iteratively refines object-centric Gaussians and splats them into a semantic occupancy grid for downstream driving perception.
Results
32.20%best IoU on nuScenes with 51,200 Gaussians
20.65%best mIoU on nuScenes with 51,200 Gaussians
+9.02%relative IoU improvement over GaussianFormer at 25,600 Gaussians
+26.4%relative mIoU improvement over GaussianFormer at 25,600 Gaussians